Chapter 14 classified quadratic forms up to
congruence, and the answer over was the inertia. A
curve like is not a quadratic form,
though: it has linear terms and a constant, and its zero
set does not pass through the origin. This section asks
what the inertia classification becomes once the origin
is given up, which is exactly the question affine
geometry was built for. Two answers come out, one for
affine changes of coordinates and one for the rigid
motions of Definition 22.4.1, and
the difference between them is the difference between
“it is an ellipse” and “its semi-axes are and ”.
Where
characteristic two bites
Everything in this section needs a field in which
, and it is
worth seeing why before any definition is written
down.
A degree-two polynomial in has a
homogeneous quadratic part, and we want to write that
part as
with
symmetric, so that Chapter 14 applies
to it. For a symmetric the coefficient of
with is . Recovering from the
polynomial means halving, which is the division by that Theorem 14.3.5 performs, and
on which the uniqueness of the symmetric matrix attached
to a quadratic form (Definition 14.3.2)
depends.
Over the
halving is not merely inconvenient; the target is not
there. Every symmetric gives and since for and squaring is additive there, this is
, the square of a
linear form. So over no expression with symmetric ever has an
term, the
polynomial is
not of that shape at all, and the ones that are have
already collapsed to squares of linear forms. There is
nothing left to classify.
So: throughout this section is a field with (Definition 0.7.2), and
from the affine classification onward . The hypothesis
will be invoked by name at each of the three places
where it does work: writing the linear part as , reading off a
symmetric , and
solving for a center.
The
equation of a quadric
Fix an origin
and a basis of the direction space, which by Proposition 22.1.3
identifies the affine space of dimension with . Every polynomial of
degree in the
resulting coordinates can then be written in one
standard shape.
A quadric is what you get when a quadratic form
is allowed to forget where the origin is.
Definition
22.5.1 (Quadric)
Let and let be an affine space of
dimension over
, identified with
by a choice of
origin and basis (Proposition 22.1.3). A
quadric polynomial on is a function with symmetric and non-zero,
and
. Its
quadratic part is the quadratic form
.
The quadric defined by is its zero set For
a quadric is called a conic.
Read the clauses. “Symmetric” is a
normalization, not a restriction:
because a matrix equals its transpose, so may always be replaced
by , and once symmetric it is determined by
(Theorem 14.3.5).
“Non-zero” excludes , where would be affine and its
zero set a flat (Definition 22.2.1)
already handled in Section 2; it is the clause that
makes the object genuinely quadratic. The factor in is a convention
we may adopt because is invertible: a linear
part is with . It pays
for itself in every formula below.
The data are recoverable from the
function. Definition 22.5.1 calls
a function, so
before speaking of “its” quadratic part or “its”
constant we must check that , and are determined by . They are, over any
field of characteristic . First . Next and , so taking recovers for each . Finally is then determined as a function of , and a
symmetric is determined by that
quadratic form (Theorem 14.3.5). So the
triple
is unique.
Examples. Over with :
- ,
with ,
, : the unit
circle.
- , with
,
, : a parabola. Here the halving convention is
visible, and is
singular.
- : the
zero set is the single point , although the
polynomial has degree .
- : the zero
set is the line , traced “twice” in the sense that has rank
and the
polynomial is a square. This is the degenerate case, and
it matters because the classification must find room for
it.
- :
the zero set is empty. Over a quadric may have no
points at all, and the classification below has two
different normal forms whose zero sets are both
empty.
Non-example by minimal change.
Replace by : the quadratic part is no longer a quadratic
form, and there is no . Replace it instead by
: now
, the clause
“non-zero” fails, and the zero set is a line, not a
quadric.
Warning. A quadric is
classified through its polynomial, not through its point
set. Over the polynomials and both have empty
zero set, and no coordinate change can be expected to
tell empty from empty; yet the two polynomials will land
in different classes below, and rightly so, because
their behavior over and their
intersections with lines differ. Everything in the
affine classification below is a statement about the
polynomial up to
an invertible affine substitution and a non-zero scalar
factor. When the zero set determines up to a scalar it will
be said explicitly.
The matrix
of a quadric
The whole point of writing the linear part as is that then becomes a single
quadratic form in one extra variable. Write so that is symmetric
and the two middle terms being equal because each
is a
matrix and one is the transpose of the other. We call
the
big matrix of and its small
matrix. The extra coordinate is the same trick
that turned an affine map into an block
matrix in Proposition 22.1.7, and
the two devices fit together exactly.
Proposition
22.5.1 (Affine Substitution Is Congruence of
the Big Matrix)
Let have big
matrix , let be
invertible, let , and let be the corresponding invertible
affine map (Definition 22.1.3), with
block matrix (Proposition 22.1.7) Then is again a quadric polynomial, its big matrix
is ,
and its small matrix, linear vector and constant are
Proof. By Proposition 22.1.7, . Hence
and
is symmetric, being a congruence of a symmetric matrix
(Proposition 14.2.4).
Multiplying the blocks out, where the bottom-left block was transposed
using .
Reading off the blocks gives , and . Finally is
non-zero, since
is invertible and congruence preserves rank (Theorem 14.2.3), so is a quadric
polynomial. This proves the proposition.
Three consequences are worth naming at once. The new
constant is
evaluated at the new origin — obvious in hindsight,
since means
. The new
small matrix is a congruence of the old one, so
the rank of is an affine invariant
of by Theorem 14.2.3, and over
so is
its inertia by Corollary 14.5.2 (b) — the
latter only up to the simultaneous exchange of with that a negative
scalar factor forces, as Step 4 of the classification
theorem below records. And itself only
undergoes congruences by matrices whose last row is
, which
is a strictly smaller set than all congruences: that
restriction is exactly why the affine classification is
finer than Chapter 14’s.
Replacing by
with
does
not change the zero set and replaces by , so a
scalar factor costs nothing geometrically and is worth
allowing alongside the substitution.
Definition
22.5.2 (Affine Equivalence of Quadric
Polynomials)
Two quadric polynomials on are affinely
equivalent when for some invertible affine map (Definition 22.1.3) and
some
with .
This is an equivalence relation, because the
invertible affine maps form a group and the non-zero
scalars do too.
Centers
A circle has a center and a parabola does not, and
the difference is visible in the equation before any
picture is drawn.
A center is a point about which the equation is
symmetric.
Definition
22.5.3 (Center of a Quadric)
Let be a
quadric polynomial on . A point is a
center of if is
central if it has at least one center,
and centerless otherwise.
In words: reflecting in , the map ,
carries the quadric to itself, and more than that,
leaves the whole polynomial unchanged. The next
proposition turns this into a linear system.
Proposition
22.5.2 (When a Center Exists)
Let and let be a quadric
polynomial on .
Then:
- (a) is a center of if and only if ;
- (b) is central if and only
if ;
in particular is
central whenever
is invertible, and the center is then the unique point
;
- (c) if is a center then for every , and the value is the same at
every center.
Idea. Expand and
subtract. Everything even in cancels and what is
left is , a linear functional of . A linear functional
vanishes identically exactly when its vector vanishes,
so the condition on is one linear equation
per coordinate. The is where is spent.
Proof.
(a) Expanding and
using ,
so that , Subtracting the two,
(22.5.1)
Since , the element is
non-zero. So is
a center exactly when for
every . Taking
shows
that this forces every entry of to vanish;
conversely makes Eq. 22.5.1 zero for every
. Hence
(a).
(b) By (a), a
center is a solution of , and such a solution exists exactly when
, equivalently
, lies in (Theorem 0.9.3). If
is invertible
then
and
is the only solution.
(c) With , the
expansion above with the sign reads If is a second
center then , so putting in the
last identity gives . This proves the
proposition.
Part (c) is the useful half. Translating the origin
to a center — that is, applying Proposition 22.5.1 with
and — gives ,
so the equation becomes
with no linear term at all, and Chapter 14 applies
verbatim. That single move is the engine of the
classification.
Example
(The parabola is centerless)
Show that over
has no center, and find all centers of .
Solution. For , and . Then
and because its second entry is
non-zero, so by Proposition 22.5.2 (b)
there is no center. Concretely, ,
which is
at
whatever is.
For , and , so
the centers are the solutions of , namely the
whole -axis. That
is right:
defines the pair of lines , and reflecting in any point of the
-axis swaps them.
And at
every one of those centers, as Proposition 22.5.2 (c)
promises.
Quick check. A quadric polynomial
on with has exactly
one center, and one with has
either none or a whole line of them. Which is it for
on
, and which
for ?
Solution. For we have
of rank
and , so the
unique center is ; indeed the curve is the circle . For
we have
of
rank and , so there is no center at all: it
is a parabola. The line of centers occurs instead for
, where
does lie in
.
The affine
classification over the reals
Now the theorem. Over we may diagonalize
the small matrix by Sylvester (Corollary 14.5.2), translate
to kill as much of the linear part as a center allows,
and then scale. What survives is a short list.
Theorem
22.5.3 (Affine Classification of Real
Quadrics)
Let be a quadric polynomial on and let , which is
because (Definition 22.5.1). Then
is affinely
equivalent to exactly one polynomial
from the following list, for one value of in the range shown,
where :
- (I) ,
with ;
- (II) , with
;
- (III) , with and .
Case (III) occurs exactly when is centerless. The
parameter that
occurs is
or , the two
being interchanged by a negative scalar factor (Definition 14.5.1).
Idea. Three moves, in this order,
and each is a result already proved.
① Diagonalize the quadratic part.
Sylvester’s law (Corollary 14.5.2) produces
coordinates in which the quadratic part is ; by Proposition 22.5.1 this
changes and
but nothing
else.
② Complete the square in the first variables. A
translation kills the linear coefficients , because
those are exactly the coordinates in which is invertible. This is
Proposition 22.5.2 read
one coordinate at a time.
③ Deal with what is left, a
polynomial in which the with appear only
linearly. If they do not appear at all, scaling clears
the constant to
or , giving (II)
or (I). If one of them does appear, it can be used as a
new coordinate that swallows the constant too, giving
(III).
That the list has no repetitions is a separate,
purely computational matter: the pair (inertia of , inertia of ) is an
affine invariant by Proposition 22.5.1, and
reading it off the three families separates them.
Proof. Step 1:
diagonalize. Write for the
inertia of (Definition 14.5.1); this
is the one
carried through Steps 1 to 3. By Corollary 14.5.2 (a) there
is an invertible with , where
has for , for and for . Substituting
and
applying Proposition 22.5.1 with
, the
polynomial becomes
Step 2: complete the square. Let
have entries
for and for , and substitute . By Proposition 22.5.1 with
, the new
linear vector is , whose -th entry for is , since there;
for it is
, unchanged.
The new constant is . So
Step 3, Case A: for every
.
Then .
If , this is . If we are in case
(II). Otherwise multiply by and reverse
the order of the first coordinates, which
turns
into with
; again
case (II).
If , substitute for and otherwise, an
invertible linear change, and then multiply by . The result is . If this is
case (I) with parameter . If , multiply
by and reverse
the order of the first coordinates to get
, case (I) with parameter .
Step 3, Case B: for some
.
Here . Put
in . Extend to a basis of (Theorem 1.6.5) and
let be the invertible matrix whose
first row is and whose
remaining rows complete it to an invertible matrix; such
rows exist because a basis of written as rows
forms an invertible matrix. Define new coordinates by
an invertible affine substitution, under which
. Hence . Replacing by and keeping the
other coordinates gives . If , multiply by , reverse the order of
the first
coordinates and replace by ; the result is
with . Either way we reach case (III).
Step 4: the list has no repetitions.
By Proposition 22.5.1 an
affine equivalence replaces by and
by
,
with and invertible. A
congruence preserves inertia (Corollary 14.5.2 (b)), and
multiplying a real symmetric matrix by leaves the
inertia alone if and exchanges with if . Hence the
invariant pair in which is the
inertia triple of Definition 17.10.1, is
an invariant of the affine equivalence class. Write
for the small matrix shared
by all three families. In family (I) the linear vector
is and the
constant is , so
; in family (II) the constant is
, so . In family (III) the linear vector is and the
constant is , so
is
diagonal except in the four positions indexed by and , where it carries the
block , whose eigenvalues are
and ; the remaining
diagonal entries are and zeros. So Therefore in all three, while is
, and respectively. Ranks
are unaffected by the exchange of and , so the pair already determines both the
family and .
It remains to separate two members of one family with
the same . If the
invariants agree without the exchange, then gives
at once.
Suppose instead they agree after the exchange, so that
.
Family (I). The exchanged
of the -member is
, while the -member has . Comparing first entries
gives ,
which is false. So family (I) has no repetitions.
Families (II) and (III). Here both members
satisfy
and , that is . Hence and .
So distinct entries of the list are affinely
inequivalent, and Step 3 showed every meets one. The normal
form reached has small matrix , of inertia
;
since is
preserved by affine equivalence up to the exchange of
with , that is or , as claimed.
Finally, is
centerless exactly in case (III): by Proposition 22.5.2 (b)
centrality is the condition , which is
preserved by affine equivalence because centers are (if
is a center of
and is invertible affine,
then is
a center of , since is a bijection of ); and is a center in cases
(I) and (II), while in case (III) the small matrix is
and the
linear vector is . This
proves the theorem.
The nine real conics
For the
parameters run over and , and the list has nine entries. Here they
are, with the zero set of each. The last column records
the classical names, and so does the paragraph on below; those names
are not defined anywhere in this book, and each
set-theoretic reading is a one-line check from the
normal form — for instance has no
real solution because a sum of squares is non-negative,
and
is the pair of lines , by factoring.
|
|
I |
|
|
ellipse |
|
|
I |
|
|
hyperbola |
|
|
I |
|
|
empty |
|
|
II |
|
|
one point |
|
|
II |
|
|
two crossing lines |
|
|
I |
|
|
two parallel lines |
|
|
I |
|
|
empty |
|
|
II |
|
|
one line |
|
|
III |
|
|
parabola |
Two rows of the table are written with the parameter
of the negated
polynomial: means , which is after
multiplying by ,
and likewise for . Reading the two inertia columns up to a
simultaneous exchange of the first two entries confirms
that no two rows agree: rows 1, 3, 4 have and differ in ;
rows 2 and 5 differ in ;
and rows 6, 7, 8, 9 have with four different .
In each of those two groups the exchange changes , so
it cannot rescue a match. The one group where
survives the exchange is rows 2 and 5, with ; there
is against
, and the
exchanged forms and still
disagree.
Rows 3 and 7 are the honest surprise: both zero sets
are empty, and both are needed, because the polynomials
are not affinely equivalent. Over they are quite
different objects. Row 7 is ,
a pair of distinct lines, while row 3 has an invertible
small matrix. Exercise (C2: Over another field)
(a) below classifies affine quadrics over , where rank alone is
the invariant and the two rows stay apart: row 3 has
and
, row 7 has and . Read projectively,
Section 10’s rank criterion makes row 3 a smooth
conic.
For the
same count gives normal forms. The new shapes are the
ellipsoid , the hyperboloids of one and two sheets , the
cone ,
the elliptic and hyperbolic paraboloids , and the
three cylinders , , , which are the
conics of the table dragged along the missing
coordinate. The rest are a pair of intersecting planes,
a pair of parallel planes, a double plane, a line, a
point and three empty sets.
Warning. The rank of does not
classify; the inertia does. The ellipse , the hyperbola
and the
empty conic all have and .
Their small matrices already differ in inertia in the
hyperbola’s case, and the ellipse and the empty conic
are told apart only by against . A count of
non-zero eigenvalues cannot distinguish a curve from
nothing at all.
Euclidean
quadrics and principal axes
Affine equivalence forgets shape: every ellipse is
affinely a circle. To keep shape, restrict the allowed
substitutions to the Euclidean motions of , which by Theorem 22.4.1 are
exactly the maps with ; that theorem gives one direction, and
the other is that such a map preserves distances, since
preserves norms
(Theorem 11.7.3).
Call two quadric polynomials Euclidean
equivalent when one is for such a
. Note that no
scalar factor is allowed now, and that is deliberate: a
scalar factor would rescale the lengths we are trying to
measure.
The gain is immediate. Under the small
matrix becomes , which is both
a congruence and a similarity, since
. So
the eigenvalues of , not merely their
signs, are Euclidean invariants. This is the observation
Chapter 12 made in Theorem 12.5.5,
and the classification below is that theorem with the
origin allowed to move.
Theorem
22.5.4 (Euclidean Classification of Real
Quadrics)
Let be a quadric polynomial on , let , and let
be the non-zero eigenvalues of , listed with
multiplicity. Then there is a Euclidean motion , with
,
after which
becomes exactly one of
- (a) , when is central, where at any center
;
- (b) , when is centerless, where
.
The columns of are an orthonormal
basis of eigenvectors of , the first of them for ; these are the principal
axes of .
The multiset and the number , respectively , are unchanged by
every Euclidean motion, so the normal form is unique up
to the order of its terms.
Idea. The spectral theorem replaces
Step 1 of Theorem 22.5.3, and it is
the only change: instead of scaling the eigenvalues away
to we keep
them, because an orthogonal matrix is not allowed to
rescale. Steps 2 and 3 then go through with one
adjustment. In Step 3 we may no longer stretch a
coordinate to absorb ; instead we
rotate the last coordinates so that
points along one
of them, which is legitimate because those coordinates
carry the eigenvalue and a rotation among
them leaves the quadratic part untouched.
Proof. Step 1. By
Corollary 12.5.2
there is with , the
eigenvalues of
with multiplicity, and we order the basis so that are the non-zero ones; the count is
right because is
similar to , so
, and a diagonal matrix has rank equal to its
number of non-zero entries. Substituting and using Proposition 22.5.1 with
gives
Step 2. Translate by with entries for
and otherwise, which is
legitimate because those are non-zero.
As in Theorem 22.5.3, Step 2,
the new linear vector has -th entry for and for . Write and for the new
constant, so
Claim: if and only if is central, and in
general . The last columns of
are an
orthonormal basis of the eigenspace of for , that is of , and the entries
of are . By Theorem 11.6.5 (b)
applied to the self-adjoint operator , we have
, so by Theorem 11.3.2 the
component of in
is , and
by Theorem 11.2.1 its
norm is .
Hence
exactly when , which is centrality by Proposition 22.5.2 (b).
This proves the claim.
Step 3, central case. Here , so , which is form (a). The new origin
satisfies by Proposition 22.5.2 (a),
because the linear part has vanished, so is a center and by
Proposition 22.5.1; Proposition 22.5.2 (c)
says the value does not depend on which center.
Step 3, centerless case. Here . By Corollary 11.2.3
the unit vector extends to an
orthonormal basis of ; let have
that basis as its columns, so and
therefore . Put ,
which lies in . Substituting
leaves
the quadratic part alone, since and turns the linear part into . Finally translate by , which
changes no quadratic term because the coefficient of
is . The
result is form (b) with .
Step 4: invariance. Let with
. By
Proposition 22.5.1, has small matrix
, which is
similar to and
so has the same eigenvalues with multiplicity (Theorem 7.10.3). Its
linear vector is . For the central case, is a center of
whenever
is a center of
, as noted at the
end of Theorem 22.5.3, and the
value there is ; so is unchanged. For the
centerless case, , and , so the component of in is applied to the
component of in
; an
orthogonal matrix preserves norms (Theorem 11.7.3), so
is unchanged.
This proves the theorem.
When is
invertible and , dividing form (a) by puts it as whenever all the ratios are
positive, which is the ellipsoid case. The
semi-axes lie along the
eigenvectors, and a large eigenvalue gives a short axis,
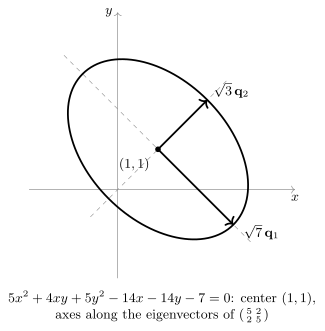
exactly as in Example (Finding the axes of a conic).
Example
(One conic, two classifications)
Over ,
consider Classify its zero set affinely, and then find
its center, principal axes and semi-axes.
Solution. The small and big
matrices are the off-diagonal being half of and the in the last column
being half of .
Center. , so by Proposition 22.5.2 (b)
there is exactly one center, the solution of ,
namely .
Then .
Affine route. By Proposition 22.5.2 (c),
translating to
gives with , . Completing the square, since . So with and
the equation
is , and the further scaling ,
gives . The inertia of is and that of is , since forces one negative eigenvalue and
supplies two
positive ones. Row 1 of the table: an
ellipse.
Euclidean route. The characteristic
polynomial of is
, so the eigenvalues are and with unit eigenvectors
as and . By Theorem 22.5.4 the motion
with
turns into ,
that is So the ellipse is centered at , with semi-axis
along and semi-axis along . Check the longer
one: the point has , and
, as required.
What each route saw. Both say “ellipse”.
Only the Euclidean one says which ellipse: the affine
route ended at a circle of radius , having first sheared
the plane by and then stretched it by the unequal
factors
and to get
there.
The two classifications answer two different
questions, and it is worth being blunt about which is
which. The affine one asks what the quadric is made
of — a curve, a pair of lines, a point, nothing —
and its invariants are two inertias. The Euclidean one
asks what the quadric looks like, and its
invariants are the eigenvalues themselves. Section 10
asks a third question, the projective one, and the
answer there is shorter than both.
Exercises
A. Check your
understanding
Exercise
(A1)
- (a) State Definition 22.5.1,
including every clause on , and say what goes
wrong if the clause “non-zero” is dropped.
- (b) Write down the
big matrix of
over .
- (c) Name the three
places in this section where is used.
- (d) True or false:
two quadric polynomials with the same zero set are
affinely equivalent. Justify your answer.
- (e) A quadric on
has and .
Which of the three families of Theorem 22.5.3 does it
belong to, and is it central?
Solution.
(a) with symmetric and non-zero, , , over a field of
characteristic . If were allowed, would be an affine
function and its zero set a flat or all of ; nothing quadratic
would remain, and Theorem 22.5.3, whose
first step diagonalizes a small matrix of rank , would have
nothing to work on.
(b) The
coefficient of
is , so ; the
coefficient of is
, so ; there is no
term, so . Hence
(c) Writing a
linear part as ; recovering a
symmetric from the quadratic
part, where the off-diagonal entries are halves (Theorem 14.3.5); and
dividing by in Eq. 22.5.1 to get the
center equation .
(d) False. Over
, and both have empty
zero set, but is for the first and for the second, and
rank is an affine invariant by Proposition 22.5.1.
(e) , so it is family (III), and family (III) is
exactly the centerless case by Theorem 22.5.3.
B. Practice
Exercise
(B1: Centers)
For each of the following quadric polynomials over
, determine the
set of centers. Justify your answer.
- (a) .
- (b) .
- (c) .
Solution. In each case solve (Proposition 22.5.2
(a)).
(a) , . Since is invertible the
center is unique: .
(b) , which has
rank with ,
and . So centers exist, and they solve
:
the line . (Consistently, the polynomial is , whose
zero set is empty but whose equation is symmetric about
that line.)
(c) Same , but . If
were in
its second entry would be times its first, and
. So
there is no center; this is a parabola.
Exercise
(B2: Affine type)
Classify the conic over : find and
,
name the row of the table, and exhibit the invertible
affine substitution that reaches the normal form.
Solution. Here and , . The eigenvalues of
are and , from , so by Theorem 14.5.3, and .
The unique center solves , giving
, and . Translating, the equation becomes
with , . Completing the square, , so with , the equation is .
Multiplying by
and setting , gives .
So
is congruent to up to the
translation, giving ; up to the simultaneous exchange this
is the invariant
of row 2. The conic is a hyperbola.
Exercise
(B3: Principal axes)
Find the center, principal axes and semi-axes of
over .
Solution. , , . Since the
center solves : from and we get , . Then
using ,
valid because .
The characteristic polynomial is , so with unit
eigenvectors and ; indeed and . By Theorem 22.5.4 the normal
form is , that is So the curve is an ellipse centered at ,
with semi-axis along and semi-axis along .
C. Going deeper
Exercise
(C1: Which quadrics are determined by their
points)
Work over
with .
- (a) Give two quadric
polynomials with the same zero set that are
not proportional.
- (b) Prove that if
is a quadric
polynomial whose zero set contains three points of some
line , then vanishes on all of
.
- (c) Deduce that the
zero set of a quadric polynomial is never exactly a set
of three non-collinear points.
Hint for (b): restrict to a parametrization of
.
Solution.
(a) Take and . Both
vanish exactly at , since a sum of
squares of reals is zero only when each is, but for
any :
comparing the coefficients of forces , and then the
coefficients of
disagree.
(b) Write with , a flat of dimension (Definition 22.2.1). Then
by the expansion in the proof of Proposition 22.5.2, so
is a polynomial
of degree at most
in . If vanishes at three
distinct points of , then has three distinct
roots. A non-zero polynomial of degree at most over a field has at
most roots (Corollary 6.1.4), so
is the zero
polynomial and
vanishes on all of .
(c) Suppose, for
a contradiction, that the zero set of a quadric
polynomial is
exactly with the three points not collinear, that
is affinely independent (Definition 18.2.1). Then
is
an affine frame of (Definition 22.2.4), so by
Theorem 22.2.8 there is
an affine map
carrying it to the frame . That is invertible: by Theorem 22.1.5 (b) its
linear part sends
to and
to , so it
carries a basis to a basis and is invertible, whence
is bijective by
Proposition 22.1.7.
Substituting by , we may therefore
assume the three points are , , , since an
invertible affine substitution carries the zero set
bijectively to the zero set (Proposition 22.5.1).
Write . Then , and
, so Restricting to the line gives . If this vanishes
identically and the whole line lies in the zero set,
which is impossible for a three-point set; so , and by the same
argument on ,
.
Now fix with and restrict to the line : The only point of on that
line is ,
because needs
and is not of the form
. So must be the only
root. If , the bracket vanishes at ,
and that must be ,
forcing .
Hence for every , The first equation is a quadratic in with leading
coefficient , so it has at most roots, and the second
has exactly one since (Corollary 6.1.4). That
is at most three permitted values of , while is
infinite. Contradiction. Hence no quadric polynomial
over has
exactly three non-collinear points as its zero set.
Exercise
(C2: Over another field)
- (a) Over , prove that every
quadric polynomial in variables is
equivalent, under an invertible affine substitution and
a non-zero scalar, to one of , , or
with ,
where . How many normal forms are there
for ?
- (b) Over , how many points
does the conic have in ? And ?
Solution.
(a) Repeat the
proof of Theorem 22.5.3, replacing
Corollary 14.5.2 by Corollary 14.4.4, which says
that over a
symmetric matrix of rank is congruent to :
rank alone is the congruence invariant. Step 1 gives
; Step 2 is unchanged; and in Step 3 Case A
with we
substitute for with , possible because every complex number has
a square root, and obtain after
dividing by .
No sign remains to normalize, and no survives, so the
invariants reduce to , which are pairwise
distinct. For :
gives three forms and gives two (family (III) needs ), so
five in all, against nine over . The four forms that
disappear are accounted for by inertia: over the ellipse, the
hyperbola and the empty conic all become
; the
point and the crossing lines both become ; and and both become
, the
last two because .
(b) The squares
in are , , , so and has two solutions
while has
one. For : either and , giving points, or and , giving points; and rules out the remaining
combination. Total 4 points, namely
and . For : the
options are
only, since and . Total 1 point, the origin.
So over this
“circle” behaves like a real circle in the first case
and like the real point-conic in the second, because
is not a square
in .
Exercise
(C3: The center as a projection)
Let be a central quadric polynomial on
with .
- (a) Prove that the
set of centers is a flat of dimension (Definition 22.2.1).
- (b) Prove that the
set of centers is contained in the zero set of if and only if for one, hence
every, center .
- (c) Give an example
on with a
line of centers, none of which lies on the quadric.
Solution.
(a) By Proposition 22.5.2 (a)
the centers are the solutions of , a consistent
linear system. By Theorem 3.1.3 its
solution set is for any particular solution , a coset of , hence a flat
with direction space . Its dimension
is by the Rank-Nullity Theorem (Theorem 2.3.1).
(b) By Proposition 22.5.2 (c)
the value is
the same at every center, so “for one” and “for every”
agree; and the set of centers lies in the zero set
exactly when that common value is .
(c) Take
on . Here
has rank , , and
the centers are the solutions of , namely the
-axis, a line as
(a) predicts with . The common value is , so
no center lies on the quadric, which is the cylinder of
radius about the
-axis.