An orthogonal matrix is normal, so the real normal
form of the previous section applies to it — and the
extra information that an orthogonal matrix carries,
that every eigenvalue has modulus , collapses that form
into something very small. What comes out is a complete
description of the rigid motions of fixing the origin:
a few axes reversed, and the rest of the space turned in
independent two-dimensional planes. In dimension this is the statement
that every rotation has an axis, and we push it as far
as an explicit formula for the rotation matrix in terms
of its axis and angle.
Throughout, carries the
standard inner product, and is a real matrix.
Two pieces of notation, both recalled. For , Chapter
11 wrote for the matrix that rotates the plane by (Theorem 11.7.6). It
is exactly the rotation-scaling block of Chapter 10 for
a complex number on the unit circle: in the notation of Definition 10.4.1,
since . And is the block
diagonal matrix with diagonal blocks and .
Now the observation that starts everything. If then
, so commutes with its own
adjoint: every orthogonal matrix is
normal. So Theorem 12.5.3
applies. All that remains is to say what the blocks can
be, and for that we use the one thing an orthogonal
matrix has that a general normal matrix does not.
Idea. is normal, so Theorem 12.5.3
already hands us a block diagonal matrix with blocks and blocks . The
blocks are unconstrained for a general normal matrix;
here they are not, because the eigenvalues of an
isometry lie on the unit circle. A real eigenvalue on
the unit circle is , and a conjugate pair on the unit circle is
,
which turns the scaling block into a pure rotation. Then
sort the s to
the front.
Proof. The operator on satisfies by
Theorem 11.6.3,
since the standard basis is orthonormal, so and likewise in the other order. Hence
is normal
(Definition 11.6.3),
and by Theorem 12.5.3
there is an orthonormal basis of in which where and with . Let be the matrix whose
columns are the vectors of . Its columns are
orthonormal, so by Theorem 11.7.3 (f),
and by Theorem 4.2.3.
The blocks. A block diagonal matrix
is triangular by blocks, so the eigenvalues of
over are the
together with
the roots of each ,
namely
and . Now
by Proposition 11.7.4
(a), so is
unitary, and every complex eigenvalue of satisfies
by Proposition 11.7.1
applied to
on . Therefore
for
each , and for
each . Since and
, there
is a unique with and , and
then .
Sorting. Let be the number of with and the number with , so .
Reordering the vectors of so that the blocks come first,
then the blocks,
then the rotation blocks in pairs, leaves the basis
orthonormal and permutes the diagonal blocks; the new
is the old one
with its columns permuted, still orthogonal. This gives
the displayed form.
The determinant and uniqueness. By
Theorem 7.5.4 and Corollary 7.5.7,
, and the determinant of a block
diagonal matrix is the product of the determinants of
its blocks (Theorem 7.8.4), which
are , and . Hence . Finally,
similar matrices have the same eigenvalues with the same
multiplicities, and reading the eigenvalues off the
displayed form gives with multiplicity , with multiplicity
, and the pairs
;
so , and the are recovered
from alone. This
proves the theorem.
So an orthogonal matrix is, up to an orthogonal
change of coordinates, nothing but a list of angles
together with a count of reversed axes. The number of reversed axes is not
itself an invariant of the geometry — a block and a block together make
, a
rotation by —
which is why the theorem demands and
keeps the s
separate. What the determinant sees is only the parity
of .
Quick check. What is the canonical
form of a with ? Compare with
Theorem 11.7.6.
Solution. Here and , so is odd, forcing , , . The canonical form
is . Chapter 11 found that such a
is the
reflection in a line
, fixing and negating ; in the
orthonormal basis of eigenvectors of Theorem 11.7.6 (b)
its matrix is exactly . Note what
the canonical form drops: the angle of the mirror. All
reflections of the plane are orthogonally similar to one
another, and Exercise (C1: The plane, re-derived)
makes this comparison precise.
Rotations
of space
In dimension
the arithmetic leaves very few possibilities, and they all
look the same.
Corollary
12.6.2 (Orthogonal Matrices in Dimension
Three)
Let . Then there are an orthonormal basis
of
and an angle
such that, in that basis, the matrix of is In particular every fixes the
line
pointwise and rotates the plane by
.
Proof. Write the canonical form of
Theorem 12.6.1,
with
and .
Case . Then is even, so . If then , giving or ; if then and . The three forms
are and in every case , so the form is
with .
Case . Then is odd, so . If then , giving or ; if then . The three
forms are , then , and .
In both cases the first basis vector spans the eigenline and is an
orthonormal basis of , which
is what the last sentence asserts when .
Chapter 11 proved the statement
directly, as Theorem 11.7.7, by
producing a real eigenvalue from the odd degree of the
characteristic polynomial and then invoking the
classification of . We do not
repeat that argument: the point here is that the same
conclusion falls out of the canonical form with no work
at all, and that the same three lines also settle . An
orthogonal matrix of determinant in dimension is a rotatory
reflection: a rotation about an axis followed
by the reflection in the plane perpendicular to it. Its
two extreme cases are the plane reflection () and the
antipodal map
().
The
cross-product matrix
The canonical form tells us that a rotation of exists in a
suitable basis. For computation we want it in the
standard basis, written directly in terms of the axis.
The bookkeeping is done by one matrix.
Recall from Chapter 7 that the cross product of is For fixed this is linear in
, so it is given
by a matrix.
Definition
12.6.1 (Cross-product Matrix)
For , the cross-product
matrix of is so that for every .
The last clause is a check of the three entries
against the formula above, with and . The map is
linear and injective, and its image is exactly the set
of skew-symmetric matrices: a skew matrix has zero diagonal and
three free entries below it, and those three entries are
. We
record the facts we need, all of them for a
unit vector.
Lemma
12.6.3 (Properties of the Cross-product
Matrix)
Let
with ,
and write . Then
- (a) and ;
- (b) , so
is symmetric
and
for every ;
- (c) ;
- (d) for every : ,
and
.
Idea. Everything follows from (b),
and (b) is one entry of a matrix product together with
. Part (c) is (b) multiplied by , where the term dies by (a).
For (d), a norm is computed through its square, and
turns (d) into
(b) as well.
Proof.
(a) Transposing
changes the
sign of each of the three off-diagonal pairs, and the
diagonal is zero. For the second claim,
directly from the formula, each coordinate being of the
form .
(b) The entry of is , using ; and
. The entry of is , and the entry is . The remaining six entries are obtained
by cycling the indices , under which both and are
unchanged in form. Hence ,
which is symmetric since .
If then
, so
.
(c) By (b) and
(a), .
(d) Let . Using (a)
and then (b), Next, is a matrix, hence equal to its own
transpose ; a number equal to its own negative
is , so . Finally
by (a).
This proves the lemma.
Part (c) is the identity that makes every power of
reduce to or , and it is the
reason Rodrigues’ formula has only three terms and no
more.
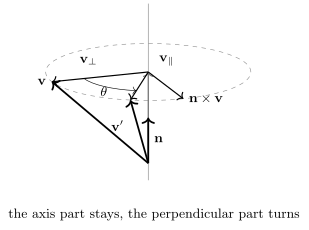
Fix a unit vector and an angle . We want a formula
for “turn space by about the axis
”. The
construction is forced by the picture: split a vector
into the part along the axis, which does not move, and
the part perpendicular to the axis, which turns inside a
single plane.
Write for the component
of along the
axis and for the component perpendicular
to it; this is the splitting of Theorem 11.3.2 for
, and
by Theorem 11.3.3 (a)
with the orthonormal basis of . Write for the vector we
want, the image of under the turn.
By Lemma 12.6.3 (d),
the vector has the
same length as and is
perpendicular to both and : it is turned by a
quarter turn inside the plane . So turning
by means taking , and . Finally , since is
a multiple of . That is the definition we take, and the
theorem says it is the right one.
Theorem
12.6.4 (Rodrigues’ Rotation Formula)
Let
be a unit vector, let , and write . Define
- (a) For every ,
- (b) ,
and for every unit the list is an orthonormal basis
of with . In particular .
- (c) Conversely,
every
equals for some
unit vector and
some .
Idea. Part (a) is the paragraph
above, read backwards: substitute
from Lemma 12.6.3 (b)
into the geometric expression and collect terms. Part
(b) then needs only the images of three basis vectors,
and every one of them is a two-line computation with (a)
and the lemma; the matrix that comes out is the
canonical form of Corollary 12.6.2,
which also gives orthogonality and the determinant for
free. Part (c) runs Corollary 12.6.2
in reverse: it hands us a basis , and the
only question is whether is or its
negative — and if it is the negative, we change the sign
of the angle.
Proof.
(a) By Lemma 12.6.3 (b),
. Hence, writing and , since . The right-hand side is
.
(b) First and by
Lemma 12.6.3 (a),
so .
Let be a unit
vector with , and put . By Lemma 12.6.3 (d),
,
and
, so
is an orthonormal list of three vectors in , hence an
orthonormal basis (Theorem 11.1.4 and
Theorem 1.6.4). Now
compute the three images. We have .
Next,
by Lemma 12.6.3 (b),
since ,
so Finally , so , and ; hence Reading off the columns (Definition 4.1.1),
. This matrix is
orthogonal, and it is the matrix of in an
orthonormal basis, so is an
isometry and by Theorem 11.7.3 (f)
and Definition 11.7.2.
The two matrices are matrices of the same operator,
hence similar (Theorem 4.2.4
(a)), so they have the same determinant (Corollary 7.5.7),
namely ; so .
- (c) Let . By Corollary 12.6.2
there are an orthonormal basis of
and with
. The vector is a unit
vector orthogonal to and by Lemma 12.6.3 (d),
and so is ;
since is a line (Theorem 11.3.2
(c)), its unit vectors are , so
with .
Case . Then (b), applied with and , gives . Operators with the same
matrix in one basis are equal, so .
Case . Then , and the matrix of in the basis is
obtained from by changing the sign of the third
basis vector, which changes the sign of the two
off-diagonal entries of the block: it is
. By the previous case, .
Finally , so and with a unit vector and
. This proves the theorem.
Part (c) is worth restating on its own: a
rotation of
is nothing but a unit vector and an angle. That
is three numbers of data, one of them redundant, for an
object that started life as nine matrix entries subject
to six equations.
Quick check. Compute from
Rodrigues’ formula and identify the map
geometrically.
Solution. With and , the
formula gives , using Lemma 12.6.3 (b).
It fixes and
negates every vector perpendicular to : the half-turn about
the axis. Equivalently , minus the Householder reflection of
Definition 11.8.1
in the plane .
Reading
off the axis and the angle
Rodrigues’ formula runs one way: from to . The inverse direction
is just as cheap, because the formula splits into a symmetric part
and a skew part that carry the two pieces of data
separately.
Theorem
12.6.5 (Axis and Angle from the Matrix)
Let with a unit vector and
. Then
- (a) ,
so and is determined by
;
- (b) ;
- (c) if ,
then and if then and the axis is arbitrary; and if then ,
whose non-zero columns are the multiples of .
Proof. Write . By Lemma 12.6.3 (b),
, so ; and
, the
diagonal of
being zero.
(a) Taking traces
in Rodrigues’ formula, which is legitimate because the
trace is linear (Theorem 0.9.6 (1)),
Since is injective on
, this
determines .
(b) By Lemma 12.6.3 (a)
and (b), and . Transposing Rodrigues’ formula therefore
gives , and
subtracting, .
(c) For we
have , so (b) may be divided by , and the
three independent entries of are ,
and by
Definition 12.6.1;
the displayed formula reads these off . If then
Rodrigues’ formula gives . If then , as computed in the Quick check
above, so , whose -th column is ; at least one
, so at
least one column is a non-zero multiple of . This proves the
theorem.
The two degenerate angles are exactly the two at
which the skew part vanishes, and they are exactly the two at
which the axis is not determined by a signed
angle: at there is no rotation to speak of, and at
turning by and
about the same
axis give the same map. Everywhere else, part (c) is a
two-subtraction recipe.
Example
(Axis and Angle of a Space Rotation)
Let Verify that , find its axis and angle, and confirm
the answer with Rodrigues’ formula.
Solution. Orthogonality.
The columns are , and
.
Each has squared norm , and the three pairwise inner products are
So by Theorem 11.7.3
(f).
Determinant. Expanding along the first row,
, so and .
Angle. , so and by Theorem 12.6.5
(a).
Axis. Here . The
three entries needed by Theorem 12.6.5 (c)
are so , which is a unit vector since
.
Check. , so the axis is
fixed. And Rodrigues’ formula with reads
, where Adding entry by entry, for instance in position and in position , returns .
Reflections generate
The canonical form is one way to say that an
orthogonal matrix is built from simple pieces. Here is
another, and the pieces are even simpler: mirrors.
Recall from Chapter 11 the Householder reflection determined by a non-zero
(Definition 11.8.1);
it is orthogonal, equal to its own inverse, and has
determinant (Proposition 11.8.2).
Lemma
12.6.6 (A Mirror Between Two Vectors of Equal
Length)
Let with and
. Then
is non-zero and .
Proof. because . Expanding the
two inner products and using , so . Hence, by the formula of Definition 11.8.1,
as claimed.
This is Theorem 11.8.3 with
the target chosen for geometry rather than for
arithmetic: there, was a prescribed
multiple of
and the sign was picked to avoid cancellation; here
is whatever we
need, and the mirror is the perpendicular bisector of
the segment from
to .
Theorem
12.6.7 (Reflections Generate the Orthogonal
Group)
Let and
.
Then is a
product of at most Householder
reflections. (The identity is the empty product, of zero
reflections.)
Idea. Induct on , and make the induction
bite by fixing one coordinate at a time. If already fixes , then it maps into itself,
and the inductive hypothesis applied inside that -dimensional space
produces at most reflections, each of which extends to a
reflection of
by taking the same . If does not fix , spend one
reflection making it do so: and are two distinct
vectors of the same length, and Lemma 12.6.6 is
exactly the tool that swaps them.
Proof. Induction on . For , a matrix
satisfies , so and ; thus , where is the empty product
and , one reflection.
Let and
assume the statement in dimension . Let and set
, a unit
vector since
is an isometry (Theorem 11.7.3).
Case 1: . Put ,
of dimension
by Theorem 11.3.2 (c).
For we
have ,
the middle equality by Theorem 11.7.3 (b);
so is -invariant.
Identify with
through
the orthonormal basis . The restriction is an isometry
of , so its matrix
in that
basis lies in (Theorem 11.7.3
(f)), and by the inductive hypothesis with and .
Let be the vector with coordinates in the basis
. Then fixes , because (Proposition 11.8.2
(d)), and on it
acts as , because
the defining formula only involves inner products, which
agree. Hence and
agree on and
on , so they agree
on , and is a product of
reflections.
Case 2: . Then , so is non-zero and by Lemma 12.6.6. The
matrix is
orthogonal, being a product of orthogonal matrices (Proposition 11.7.4
(a)), and . By Case 1, is a product of
at most
reflections. Multiplying on the left by and using (Proposition 11.8.2
(b)), a product of at most reflections. This
completes the induction.
Counting reflections recovers the determinant: each
factor contributes (Proposition 11.8.2
(e)), so a product of reflections has
determinant ,
and an element of needs an even
number of them. The bound is sharp — is a product of
reflections and
no fewer, since a product of reflections fixes the
intersection of
hyperplanes, a subspace of dimension at least , while fixes only .
Composing
rotations
Two rotations of the plane about the origin compose
into a rotation, and the angles add: , so is abelian
(Chapter 11). The reason is visible in the canonical
form: in dimension there is only one
rotation block, so a rotation is a single number, and
numbers commute.
In dimension
the picture changes completely, because there is an axis
to move as well as an angle to add.
Example
(Two Quarter Turns in Two Orders)
Let and , the quarter turns about the
first and third coordinate axes. Compute and , and find the axis
and angle of each.
Solution. From Theorem 12.6.4
(b), fixes and turns the -plane by
, and fixes and turns the -plane by
: Multiplying, These are different matrices, so is not abelian.
Both have trace ,
so both are rotations by the angle with , that is . Their
axes differ. Solving gives , , , so the axis of is ;
solving
gives ,
, , so the axis of
is . Same
angle, different axes: the order of two quarter turns
changes where the resulting axis points.
That the product is again a rotation is not
an accident of this example: is a group (Proposition 11.7.4),
so any product of rotations is orthogonal with
determinant , and
Corollary 12.6.2
makes it a rotation. What no formula makes obvious is
which one; Exercise (C2: Products of rotations)
pursues this.
Warning. In dimension and above, does not mean
“rotation about an axis”. Take Its canonical form is itself, with and , so is not an eigenvalue
and fixes no
non-zero vector at all: there is no axis. Worse, the two
angles are different, so is not a rotation “in
a plane” either — it turns two orthogonal planes at two
different speeds, and no single angle describes it.
Chapter 11 made the same point with ; the
canonical form explains it, since for even the counts are allowed.
The clean statement “determinant means a rotation about
an axis” is a feature of dimension , where is odd and
forces when
is even.
Exercises
A. Check your
understanding
Exercise
(A1)
- (a) State the
canonical form of an element of , saying what the
blocks are and which angles are allowed.
- (b) Which hypothesis
on turns the
rotation-scaling blocks of the real normal form into
rotation blocks, and why?
- (c) Write down the
cross-product matrix and state the
identity for a unit .
- (d) Given , how do you
find its angle, and how do you find its axis? Name the
two degenerate cases.
- (e) True or false:
if
and ,
then fixes a
non-zero vector. Justify your answer.
- (f) How many
Householder reflections can be needed to write an
element of , and what does
the parity of that number say?
Solution.
(a) By Theorem 12.6.1,
for some , with
and
. The angles and are excluded because
and
are already accounted for by the blocks.
(b)
Orthogonality. An orthogonal matrix is unitary as a
complex matrix (Proposition 11.7.4
(a)), so each of its eigenvalues has modulus (Proposition 11.7.1).
A block has
eigenvalues , so
and the scaling factor is .
(c) has rows , , (Definition 12.6.1),
and when (Lemma 12.6.3
(c)).
(d) The angle
from the trace, with ; the
axis from the skew part, (Theorem 12.6.5).
The degenerate cases are , where and there is no
axis to find, and , where the skew part vanishes and one reads
off
instead.
(e) False for
even . The matrix
has no eigenvalue . It is true for odd
: then is odd and
is even, so is odd,
hence , and
the block
supplies a fixed vector.
(f) At most (Theorem 12.6.7).
Each reflection has determinant , so the number used
has the same parity in every such factorization as the
sign of
dictates: even for , odd for .
B. Practice
Exercise
(B1: Axis and angle)
For each of the following, decide whether it lies in
, , or neither. For those in , find the axis and
the angle; for those in with determinant
, give the
canonical form and say what the map is
geometrically.
- (a) .
- (b) .
- (c) .
- (d) .
Solution.
(a) The columns
,
,
have squared norms
and pairwise inner products , so the matrix is orthogonal. Expanding along
the first row, , so it lies in . Its trace is
, so and . For the axis, , and ; dividing by gives
. Check: .
(b) The matrix is
symmetric. Each column has entries in some
order, so each has squared norm , and the pairwise inner products are ; so it is orthogonal. Expanding along the
first row, , so it lies in . Its trace is
, so and : a half-turn. The skew part is , so use with . Check: .
(c) This is the
negative of (b), so it is orthogonal with . Its trace is , and for the form
the trace is , so and : the canonical
form is , a reflection. Indeed it equals
with , the reflection in the plane
.
(d) Neither. This
is (a) with the entry changed from
to . The third column has
squared norm , so the columns are not orthonormal and the
matrix is not orthogonal (Theorem 11.7.3
(f)). Its determinant is , neither
nor , which settles it a
second way (Proposition 11.7.4).
Note that checking the determinant alone is never
enough:
does not make a matrix orthogonal.
Exercise
(B2: Mirrors)
- (a) Write the matrix
as a Householder reflection , and say which
plane is its mirror.
- (b) Following the
proof of Theorem 12.6.7,
write as a product of Householder
reflections, and check the count against .
Solution.
(a) exchanges and and fixes . By Lemma 12.6.6 with
and , take ; then and The mirror is , the
plane .
(b) ,
so we are in Case 2 with and : Then , which fixes
and exchanges
and ; the computation of
(a), with the indices shifted, shows that it is for . Hence , a product of two
reflections. The count is even, matching ; and
indeed is the
rotation by
about found
in Example (Two Quarter Turns in Two Orders).
Exercise
(B3: Rodrigues in an example)
- (a) Compute from
Rodrigues’ formula and check that it is .
- (b) Compute for , and identify the resulting matrix.
Solution.
(a) With we have and . Hence the diagonal entries being twice and once. This is ,
the rotation of the -plane, as it must be.
(b) Here
and . Writing , so that
and
, Adding to these two gives
plus the skew part. The first
piece has on the
diagonal and elsewhere, and
adding the skew part turns each off-diagonal pair into
: This is the cyclic shift , which is the matrix of Example (Two Quarter Turns in Two Orders):
same axis ,
same angle .
C. Going deeper
Exercise
(C1: The plane, re-derived)
- (a) Use Theorem 12.6.1 to
prove that every is either orthogonally similar to
for a
unique , or orthogonally similar to .
- (b) Chapter 11
proved more:
equals or (Theorem 11.7.6).
Explain exactly what information (a) loses, and why the
canonical form must lose it.
- (c) Deduce that any
two reflections of are orthogonally
similar, and that and are
orthogonally similar if and only if .
Solution.
(a) With , . If then and the form is
with
. If then , giving , and . So the
possibilities are with and
, and
they are distinguished by the determinant. Uniqueness of
follows from
Theorem 12.6.1, or
directly from and the injectivity of on .
(b) Part (a)
determines only
up to orthogonal similarity, that is, up to a change of
orthonormal coordinates. It therefore cannot see
which line is the mirror of a reflection, nor
the sign of the angle of a rotation. It must lose the
mirror, because the mirror moves: if is the rotation by
then , so all the are
conjugate. It must lose the sign of the angle, because
conjugating by sends to .
(c) Every
reflection has determinant , so by (a) each is
orthogonally similar to , and
orthogonal similarity is an equivalence relation, so any
two of them are similar to each other. For rotations: if
then or , so they are
orthogonally similar. Conversely, similar matrices have
equal traces (Theorem 4.2.5),
so , which for real angles means
modulo .
Exercise
(C2: Products of rotations)
- (a) Prove that the
product of two rotations of is a rotation of
, and explain
which theorem supplies the axis.
- (b) Let and be the half-turns
about two perpendicular axes and , with unit vectors.
Prove that is
the half-turn about the axis .
- (c) Deduce that
every rotation of is a product of two
half-turns.
Hint for (c): use Theorem 12.6.7, or
the description of a half-turn in the Quick check after
Theorem 12.6.4.
Solution.
(a) is a group (Proposition 11.7.4
(c)), so if then . By Corollary 12.6.2,
fixes a line
pointwise and rotates the perpendicular plane; that
corollary is what supplies the axis, and it does so
through the count in the canonical form.
(b) Extend to an
orthonormal basis of , where we may take
:
it is a unit vector orthogonal to and by Lemma 12.6.3 (d).
By the Quick check after Theorem 12.6.4,
fixes and negates , so in the
basis ,
is and
is . Their
product is , which fixes and negates : the half-turn
about . (Its trace is , confirming through Theorem 12.6.5
(a).)
(c) Let , with a unit vector and
(Theorem 12.6.4
(c)). Choose a unit , and work throughout in the orthonormal
basis of Theorem 12.6.4
(b), in which
has matrix . Put , again a unit vector perpendicular
to , since fixes
and is an
isometry; by Theorem 12.6.4 (b)
its coordinate vector in is . Let and be the half-turns
about and , so that in
their matrices
are
and respectively, by the Quick check after Theorem 12.6.4.
Using , and , Multiplying the two matrices blockwise, has matrix which is the matrix of in the same basis.
Hence .
Exercise
(C3: Moving one point of the sphere to another)
Let .
- (a) Prove that for
all
there is with . (One says that acts
transitively on .)
- (b) Prove that , and that
this set is an abelian subgroup of .
- (c) Is the analogue
of (a) true for acting on the unit
circle of ?
And for
acting on the unit sphere of ? Justify your
answers.
Solution.
(a) Extend to an orthonormal
basis of (Corollary 11.2.3),
and likewise extend to . Let
and ; both are orthogonal,
since their columns are orthonormal (Theorem 11.7.3
(f)). Replacing by changes the sign of
and keeps
the basis orthonormal, so we may assume , and likewise
. Put
. Then
and
by Theorem 7.5.4 and Theorem 7.4.5, so
; and
,
because the entries of are the inner
products of with
the columns of ,
so .
(b) Each lies in
and fixes
, by Theorem 12.6.4
(b). If
fixes
, write with
(Theorem 12.6.4
(c)). If
then . Otherwise the fixed space of is exactly the line
, since in
the basis of Theorem 12.6.4 (b)
the matrix is and fixes no
non-zero vector for ; so , and gives .
For the group claim: all these matrices are
simultaneously in the same orthonormal
basis , and , so
the set is closed under products and inverses and is
abelian.
(c) Yes for : given unit , write
and and take ,
which is in
and sends to
. Yes for as well, by the
same argument as (a): extend and to orthonormal bases
of , fix the
determinants to
by flipping the sign of the last vector if necessary,
and take . Nothing in that argument used the
dimension —
transitivity holds for with . What is special
to is the
classification of the maps themselves, not their ability
to move one unit vector to another.