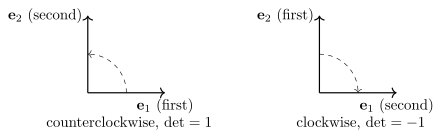The chapter began in §1 with a picture: the area of a
parallelogram, with a sign attached, obeys a few simple
rules, and those rules pinned down . We have since
built the determinant in every size from the same rules.
It is time to return to geometry and say precisely what
the determinant measures. There are two halves to the
answer. Its absolute value measures volume, and its sign
measures orientation, the difference between a left hand
and a right hand. Both halves need care. “Volume” in
has no
meaning until someone defines it, and “orientation” has
no meaning at all over .
Throughout this section the field is .
What should
the volume of a parallelepiped be?
For vectors , the
parallelepiped they span is the set
For
it is the parallelogram with sides at the origin,
and for a
slanted box. For it is the segment from to .
We would like to say “its volume is ”.
But a theorem needs two sides, and one side is missing:
we have no definition of the volume of a subset of . School geometry
supplies one for and through “base times height”, and the proper
general notion, Lebesgue measure, belongs to a course in
measure theory. So we proceed honestly in three steps.
We define the volume of a
parallelepiped by the determinant. We
prove that this is the only function
obeying the rules that any reasonable notion of volume
must obey. And we state, without proof,
that it agrees with Lebesgue measure.
The volume of a parallelepiped is the size of the
determinant of its edge vectors.
Definition
7.9.1 (Volume of a Parallelepiped)
Let and
. The (-dimensional)
volume of the parallelepiped spanned by
is
In words: stack the edge vectors as the
columns of a square matrix, take its determinant, and
forget the sign. There must be exactly vectors in
, so that the
matrix is square.
Examples.
- The unit cube has volume .
- A box with edges
has volume by Theorem 7.4.6: the
product of its side lengths, as it should be.
- The parallelepiped spanned by , , in has volume expanding along the first row.
- Degenerate case. If are
linearly dependent, the parallelepiped is flattened into
a proper subspace, and its volume is by Theorem 7.2.1. For
, is the
segment from
to , with
area . This case matters: “volume zero” is the
geometric face of “not invertible”.
Non-example by minimal change. Drop
one vector: and span a genuine parallelogram in , but the matrix
is and has no
determinant. The clause that fails is exactly
vectors in . The -dimensional volume of
that flat parallelogram would be , and its area needs a
different formula (Exercise (C1: Area of a triangle in space)).
Why this definition. Reordering the
vectors multiplies the determinant by a sign (Theorem 7.2.1), which
the absolute value removes, so the volume does not
depend on the order in which the edges are listed. The
absolute value is also what makes volume non-negative.
The sign we threw away is not garbage: it is the
orientation, the subject of the second half of this
section.
Warning. Volume is not
linear. Scaling one edge by
doubles the
volume, but scaling the whole parallelepiped by multiplies it by : ,
where has
columns . A cube of side in has volume , not ; this failure persists
even with the sign kept, since is linear in each
edge separately, not in all edges at once. The absolute
value also destroys additivity in a single edge: is in general not : with , in and , the left
side is and the
right side is .
Volume is
forced by its rules
Why should anyone accept Definition 7.9.1?
Because of what any notion of volume of parallelepipeds
must satisfy. The pictures in §1 showed three facts
about area, and they have obvious -dimensional versions:
stretching one edge by a factor multiplies the volume
by ;
sliding one edge parallel to another (a shear) does not
change the volume; and the unit cube has volume . The next theorem says
that these three rules alone determine the volume
completely. So any definition that obeys them, whether
from school geometry or from measure theory, must agree
with ours.
Theorem
7.9.1 (Volume Is Determined by Its
Rules)
Let , and
let be a function
assigning a real number to
every list of
vectors in .
Suppose that for every list, every and every :
- (V1) (only slot changes);
- (V2) (only slot changes);
- (V3) .
Then for every list.
Moreover,
itself satisfies (V1)–(V3).
Idea. Think of as a function of the
matrix with
columns . ① If the columns are dependent, shear one
column to and
scale by : . ② Each elementary
column operation changes by the factor .
Scaling and shearing are (V1) and (V2); a swap is not
among the rules, but three shears and a sign change
perform it. ③ An invertible is a product of
elementary matrices, so peel them off one at a time
until only is
left.
Proof. For with
columns , write .
Step 1: dependent columns give .
Suppose the columns are linearly dependent. By Theorem 1.4.1, some
(for , ). Applying (V2)
to slot with the
scalars , one at a time, does not change , and it replaces by while the other slots
stay fixed. Then (V1) with gives . Hence .
Step 2: for every
elementary matrix . By Theorem 3.4.1 and
Theorem 0.9.5, ,
and is the
elementary matrix , or when is , or . So right
multiplication by performs a column
operation: swap columns and ; multiply column by ; or add times column to column . The determinants are
,
and by Theorem 7.5.1.
- For , (V2) gives .
- For , (V1) gives .
- For , watch only slots and , holding and . By (V2) three times,
leaves unchanged, where the
second step subtracts slot from slot and the third adds slot
to slot . By (V1) with on slot , at equals times
at . Hence .
Step 3: conclusion. If the columns
of are
dependent, then by Step 1 and by Theorem 7.2.1, so
. Otherwise is invertible by Theorem 3.4.4,
hence is a product of elementary matrices by the
same theorem. Applying Step 2 times, starting from
, and then (V3),
where the third equality uses Theorem 7.5.4 and
. This proves .
Finally,
satisfies (V1) because the determinant is linear in each
column (Theorem 7.4.3) and
; (V2) by Theorem 7.2.1; and
(V3) because .
Agreement with area and volume from
school. For , let be the area of the parallelogram in the
sense of school geometry, base times height. The
pictures of §1 are exactly (V1)–(V3) for this : stretching a side by
stretches the
base or the height by ; a shear
slides the opposite side along a line parallel to the
base , keeping
base and height; and the unit square has area . Hence, by Theorem 7.9.1, school
area equals . For the same argument works with “area of base
times height”. What the theorem cannot supply is the
geometric input itself: it takes the three rules as
given.
Agreement with Lebesgue measure. In
measure theory, every reasonable subset has an
-dimensional
volume, its Lebesgue measure. One can prove that the
Lebesgue measure of satisfies (V1)–(V3), and hence
equals . We state this without proof; nothing in
this book depends on it.
Quick check. Which of the rules
(V1)–(V3) does the function on break?
Solution. It satisfies (V2), since
shears do not change the determinant, and (V3), since
. It breaks
(V1): , while . So the theorem does
not apply, and indeed .
Linear maps
scale volume
Applying a linear map to a parallelepiped gives
another parallelepiped: by linearity, , so . How does the volume change?
Multiplicativity answers this in one line, and the
answer does not depend on the parallelepiped.
Theorem
7.9.2 (Linear Maps Scale Volume by )
Let and . Then In particular, the image of the unit cube
under has volume
.
Proof. Let be the matrix of in the standard basis,
so for
all (Theorem 4.1.1)
and (Definition 7.5.1).
Let . By
Theorem 0.9.2, . By Theorem 7.5.4, For the unit cube take , with .
This is the meaning of the determinant of a real
operator: the factor by which it scales every
volume. An operator with squashes into a
lower-dimensional subspace, where -dimensional volume is
. In multivariable
calculus the same fact, applied to the linear
approximation of a smooth map, becomes the Jacobian
factor in the change-of-variables formula for
integrals.
Example
(Area of an Image)
Let be . Find the area of the image
of the unit square, and of the image of the
parallelogram .
Solution. The standard matrix is
, with . By Theorem 7.9.2 the
image of the unit square, the parallelogram spanned by
and , has area . The parallelogram
has area , so its image has area . Check
directly: and , and .
Orientation
Now the sign. In , the ordered basis
turns
counterclockwise from its first vector
to its second, while turns clockwise. No rotation carries one
arrangement to the other: a rotation of the plane keeps
counterclockwise turns counterclockwise. The determinant
sees the difference: and .
To compare two bases of an arbitrary real space, we
compare them with each other rather than with a fixed
standard basis, using the change-of-coordinates matrix
of Chapter 4.
Two bases have the same orientation when the
matrix converting one into the other has positive
determinant.
Definition
7.9.2 (Orientation)
Let be a
vector space over with , and let
and be
ordered bases of . We say and have the same
orientation if and opposite orientations if
.
In words: write each vector of in coordinates with
respect to , put
the coordinate columns side by side (Definition 4.2.1),
and look at the sign of the
determinant. Exactly one of the two cases occurs,
because is
invertible (Theorem 4.2.1
(c)), so its determinant is non-zero (Theorem 7.5.2), and a
non-zero real number is either positive or negative. The
bases must be ordered: reordering a
basis can change the answer.
For
there is a shortcut. If and are the matrices whose
columns are the vectors of and , then
and for the standard basis . By Theorem 4.2.1 (b)
and (c), . Since (Theorem 7.5.4), . So and have the same
orientation if and only if and have the same
sign.
Examples.
- In , and have
opposite orientations: and .
- In , and
have the same orientation. The second
matrix is the permutation matrix of a -cycle, whose sign is
. A
cyclic shift of three vectors is two swaps.
- In , the bases and have and , so , with determinant . They have opposite
orientations. Orientation makes sense in any real space,
with no picture at all.
- Degenerate case, . Bases of
are single
non-zero numbers , and . So and have the same
orientation exactly when and have the same sign. The
two orientations of a line are its two directions.
Non-example by minimal change. In
, has the
same orientation as : , and indeed it is the rotation of by a
half-turn. Change only one sign, to
: the
determinant becomes , and the orientation
flips. What changed is the sign of the determinant,
which is the whole content of the definition. In , by contrast, has determinant
: negating all
three vectors reverses orientation.
Why this definition. Using the
change-of-coordinates matrix, rather than the matrices
and above, makes the
definition work in every real space, including spaces
like
that have no standard picture. Requiring rather than
is what
gives a coarse, two-valued answer: rescaling a basis
vector by a positive number should not change its
handedness.
The payoff is that “same orientation” really sorts
all bases into two families, as the pictures
suggest.
Theorem
7.9.3 (There Are Exactly Two
Orientations)
Let be a
vector space over with .
- (a) “Having the same
orientation” is an equivalence relation on the set of
ordered bases of .
- (b) It has
exactly two equivalence classes. If
, then lies in the class
not containing .
Idea. The three axioms are three
facts about change-of-coordinates matrices: ;
the matrix back is the inverse; and matrices compose
along a chain . Determinants turn these into ,
and . For “exactly two”,
flipping one vector gives a second class, and “negative
times negative is positive” shows there is no third.
Proof. Write . By Theorem 4.2.1 (b)
and Theorem 7.5.4, for
bases ,
(a)
Reflexive: , so . Symmetric: by with , , so , which is positive when
is.
Transitive: if and
,
then by , since a product
of positive reals is positive. By Definition 0.5.2, this
is an equivalence relation.
(b) At least
two classes. is a basis, and
, because and
. Its determinant is by Theorem 7.4.6. So
, and and lie in different
classes.
At most two classes. Let and be bases, neither of
which has the same orientation as . Then and
,
and by symmetry as well. By , is a product of two negative reals, hence
positive. So all bases outside the class of lie in one class, and
there are exactly two classes.
Choosing one of the two classes is called
orienting ; its bases are then
called positively oriented, and the
others negatively oriented. On the standard choice
is the class of . By the shortcut above, is
positively oriented if and only if . So the
determinant of a real square matrix carries two
independent pieces of information: its absolute value is
a volume, and its sign is an orientation.
Warning. Orientation needs
. The
proof used two facts about the reals: every non-zero
number is positive or negative, and products and
inverses of positive numbers are positive. Over there is no such
splitting. Suppose we tried “ and have the same
orientation if has positive real part”. In , with , the bases
, , give and , both with real part , but has real part : transitivity
fails. Over ,
, so the
second basis
of the proof is
itself. The theorem holds verbatim over any field with a
compatible order, such as , but not over or a finite
field.
Quick check. Do and
have the same orientation? Does have the
standard orientation of ?
Solution. and . The signs
differ, so the two bases have opposite orientations. The
first has negative determinant, so it is negatively
oriented: it is not in the class of
.
The
right-hand rule
In , the
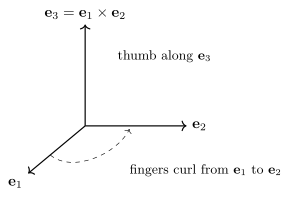
standard orientation is the one described by the right
hand: curl the fingers of the right hand from the first
basis vector toward the second, and the thumb points
along the third. For with the usual picture of the axes,
this is the familiar arrangement below.
The cross product of and
in is Physics defines it by the right-hand rule.
Here is the linear-algebra reason the two descriptions
match: is always positively oriented.
Expand along its
third column (Theorem 7.6.1). The
cofactors of that column are ,
and , which are exactly the three
components of . Hence If and
are linearly
independent, the matrix has rank , so one of its minors, which
are the
components of , is non-zero (Theorem 7.7.1). Then
the determinant is strictly positive, so is
a basis (Theorem 7.5.2) with
the standard orientation. For example, , matching the picture.
Orientation-preserving maps
An invertible operator carries each basis to a basis.
Does it keep the orientation? The answer is the same for
every basis and depends only on the sign of .
Proposition
7.9.4 (Determinant Sign and Orientation)
Let be a
vector space over with , let
be
invertible, and let be any basis of . Then is a basis of , and Hence
and have the
same orientation if and only if , and this
does not depend on .
An invertible operator with is
orientation-preserving, and one with
is
orientation-reversing. Rotations of the
plane preserve orientation and reflections reverse it
(Exercise (C2: Rotations and reflections)).
In , the map
reverses orientation, since : a right
hand, pushed through the origin, becomes a left
hand.
Exercises
A. Check your
understanding
Exercise
(A1)
- (a) State the
definition of the volume of the parallelepiped spanned
by , and say what it is when the vectors are
dependent.
- (b) True or false:
. Justify your answer.
- (c) Which three
rules characterize volume in Theorem 7.9.1?
- (d) True or false:
if ,
then doubles
every volume. Justify your answer.
- (e) Define “same
orientation” for two ordered bases of a real vector
space.
- (f) True or false:
for every ,
the map on reverses
orientation. Justify your answer.
Solution.
(a) (Definition 7.9.1).
For dependent vectors it is , by Theorem 7.2.1.
(b) False. With
, , , : the left
side is , the right side is . The absolute
value destroys additivity.
(c) (V1) scaling
one vector by
scales the volume by ; (V2) adding a multiple of one vector
to another does not change it; (V3) the unit cube has
volume .
(d) True. By Theorem 7.9.2, . The sign
only affects orientation.
(e) and have the same
orientation if (Definition 7.9.2).
(f) False. , so
by Proposition 7.9.4 the
map reverses orientation for odd and preserves it for
even . In it is the rotation
by a half-turn.
B. Practice
Exercise
(B1: Volume of a parallelepiped)
Find the volume of the parallelepiped in spanned by , and . Hence find the
volume of its image under the map .
Solution. Expanding along the first
row, so the volume is . The standard matrix of
is , upper triangular with
determinant (Theorem 7.4.6). By Theorem 7.9.2 the
image has volume .
Exercise
(B2: Comparing orientations)
In , let
, and . Determine which pairs have the same
orientation, and which are positively oriented. Justify
your answer.
Solution. By the shortcut after Definition 7.9.2,
compare signs of the determinants of the matrices with
these columns. Expanding along the first row: the second by expanding along the last row:
. The
list is shifted cyclically,
;
moving the last column to the front takes two column
swaps, so by Theorem 7.2.1 its
determinant is . Hence and are positively
oriented and have the same orientation; is negatively
oriented, opposite to both.
Exercise
(B3: Areas of images)
Let on .
- (a) Find the area of
the image of the unit square under .
- (b) Find the area of
the image of the parallelogram , first
by Theorem 7.9.2 and
then directly.
- (c) Is
orientation-preserving?
Solution.
(a) The standard
matrix has
determinant , so the image of the unit square has area
.
(b) , so the image has area . Directly,
and , and .
(c) Yes: , so by
Proposition 7.9.4
preserves
orientation.
C. Going deeper
Exercise
(C1: Area of a triangle in space)
For , let . We define the
area of the parallelogram
to be ; Chapter 13 justifies this with inner
products, where is
recognized as a Gram determinant.
- (a) Show that , so
the square root exists, and that .
- (b) Show that if
and lie in the plane , this area equals
the area of Definition 7.9.1 in
.
- (c) Find the area of
the triangle with vertices , , .
Hint: apply Corollary 7.7.3 to
.
Solution.
(a) and , so by Corollary 7.7.3
applied to ,
. The minors of
are , , for ; squaring removes the signs, giving the
stated sum.
(b) If , two of the
three squares vanish, and . Hence , which is .
(c) The triangle
is half of the parallelogram spanned by and . By (a), . As a check,
has
determinant . So the parallelogram has area , and the triangle has
area .
Exercise
(C2: Rotations and reflections)
For , let
(rotation by ) and (reflection in the line
through at angle
).
- (a) Show that every
rotation preserves orientation and area, and every
reflection reverses orientation and preserves area.
- (b) Show that is
orientation-preserving for all . (It is
in fact a rotation, but you need not show this.)
- (c) Prove that no
satisfies . Does the same argument rule out
?
Solution.
(a) and . By Proposition 7.9.4,
rotations preserve and reflections reverse orientation.
Both have , so both preserve area by Theorem 7.9.2.
(b) By Theorem 7.5.4, .
(c) If , then by Theorem 7.5.4,
impossible for a real number . The argument
says nothing about , since ; and
indeed . An
orientation-reversing map can never be the square of a
real map, since the square of anything preserves
orientation.